Nanosecond time sync over Bluetooth

PToB applies Precision Time Protocol (PTP) principles to BLE-enabled MCUs, using radio-event timestamps and follow-up data for sub-1 µs time transfer over Bluetooth.

62.5 ns one-relay PPS-shadow RMS.
GM → T096 (nRF52) intermediary → T096 receiver.Results depend on the MCU’s timing path. (PDF)

Explore the timing network

T096 AGrandmasterIndependent source
ESP32 BReceiverRoot A
T096 CReceiverRoot A
ESP32 DReceiverRoot A
Bluetooth Low Energy Packet label = sender / root source

V14 grandmaster A broadcasts timing events and later corrections. Receivers synchronize their local clocks through passive reception.

V14 · illustrative topology

Public reception · Receive time without pairing.

Boundary-clock mesh · Regenerate time while preserving root provenance.

GM elections · Select an authorized time source.

How PToB synchronizes a clock

A receiver timestamps a radio event and uses follow-up data to recover its transmit instant. A Software PLL tracks offset and drift between heterogeneous devices, synchronizing each local clock. The timing path and calibration determine precision.

  1. Broadcast

    A time source publishes an event over BLE.

  2. Capture

    A capable receiver timestamps the physical radio event.

  3. Correct

    Follow-up data identifies the original transmit instant.

  4. Synchronize

    The receiver disciplines its own clock to the source.

Basic scanners can use the broadcast time. Higher precision requires hardware timestamps and a calibrated clock model.

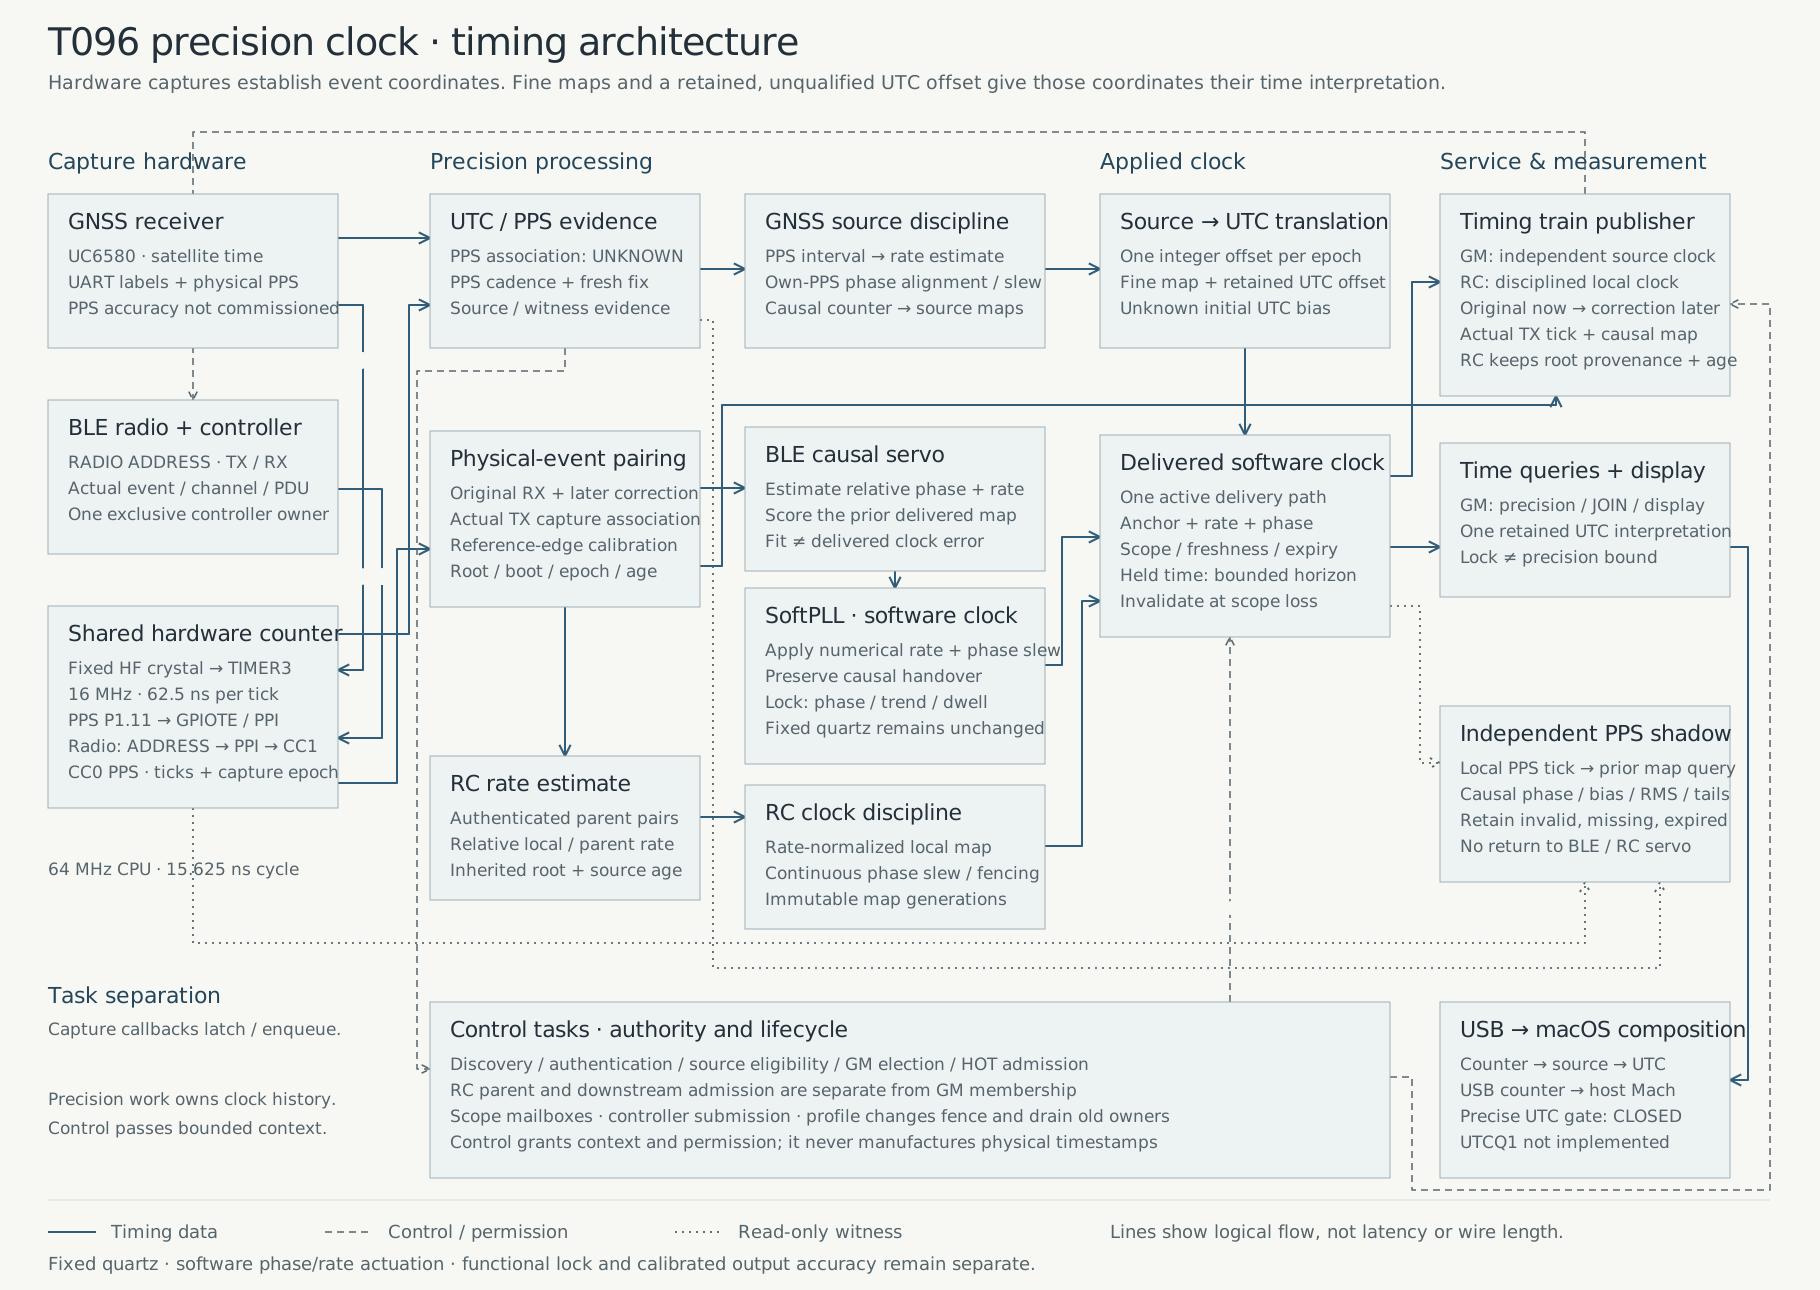
T096 timing architecture

Follow hardware capture through the servo, SoftPLL and delivered clock. Explore each mode and trace drift or offsets.

Open the interactive schematic

Explore the protocol, packet by packet

Follow a source through a dedicated relay clock to a client. Match each original event with its later correction, then inspect V14’s exact bytes and clock-age rules.

Open the V14 packet explorer

V14-RC1 synthetic examples. Physical precision remains unqualified.

One 62.5 ms timing frame

Source → RC → client
SourceGM · TX
RC 1RC · TX
ClientClient · RX
New events at each clock. The RC’s nominal slot follows the root by 15.625 ms. Its later correction carries local map generation and inherited age. Marks are widened for visibility; their widths are illustrative.

Measured timing on BLE-enabled MCUs

Nordic’s nRF52840 captures physical radio events; the ESP32-S3 W12 uses empirical receive-active capture. These separate experiments query delivered BLE time against local PPS witnesses. Each retains its own path, date and coverage.

nRF52

Nordic · T096 (nRF52840)
62.5 nsOne-relay PPS-shadow RMS

A grandmaster, relay clock and receiver distribute time across two BLE links, measured against an independent local PPS witness.

Absolute P95 / maximum
123.25 / 191 ns
Usable / nominal observations
436 / 602 · 72.425%
Platform
Heltec T096 · nRF52840

ESP32-S3

Espressif · W12
60.3 nsW12 relative-PPS RMS

W12 checks its delivered BLE clock at local GNSS PPS edges. GNSS observes the clock without training it; the full result retains the source-transition gap.

Absolute P95 / maximum
122 / 180 ns
Eligible / logged observations
522 / 600 · 87.0%
Platform / windows
W12 · ESP32-S3 · 2 × 300 s
Separate sampled shadow holdover
64 s · P99 760 ns · 128 prefixes

The stable second window reached 38.3 ns RMS across 300/300. After W12’s relay, T096 measured 61.9 ns RMS across 451/600, with a 211 ns maximum.

Read the W12 results and TX limits

The 30 October holdover study separately reaches 75 s in a fixed cohort, failing at 76 s; later rolling windows end at 24 s. Sampled holdover does not guarantee continuous accuracy.

How these numbers are measured

A PPS-shadow measurement queries the receiver’s already-published BLE clock at a separately captured pulse-per-second (PPS) edge on the same hardware counter. The reference validates the BLE clock and does not train it.

The 12 October T096 one-relay result is 62.504 ns RMS including bias over 436/602 usable/nominal boundaries. The 24 October W12 result is 60.3 ns RMS including bias over 522/600 logged PPS observations. All 78 unavailable records and the 180 ns maximum remain; the stable 300-sample window is reported separately. Inspect every W12 window and population.

After the W12 relay, T096 delivered PPS phase is 61.9 ns RMS over 451/600 with a 211 ns maximum. The separately sampled TX check scores 58/120 selected transmissions: 108.3 ns RMS and a 226 ns maximum, with 61 missing matches and one lacking PPS brackets. These have different measurement paths and denominators.

RMS is not a worst-case bound or UTC certification. Physical output, RF endpoint and absolute UTC accuracy remain unqualified. Calibration transfer to other W12 units and profiles is unmeasured. Earlier direct results remain separately dated.

Read the hardware guide

Four ESP32-S3 targets: W12, CoreSE Precision Clock, StickS3 and CoreClock. CoreSE adds a touchscreen clock, six diagnostic pages and a separate shadow holdover instrument. CoreClock is not publicly available.

How PToB compares

PToB uses nRF52 and ESP32-S3 platform timing features that can be reused in compatible devices. Compare the measured target configurations with other BLE timing research.

Reported wireless synchronization results. Statistics and measurement methods differ between studies.
ApproachTransport & hardwareReported precisionMeasurement & conditionsProtocol / standard
ESP32-S3 · PToB24 October 2026Passive BLE advertisingMeshnology W12 · ESP32-S3 receiver
60.3 ns
Delivered relative-PPS RMS · includes biasP95 122 ns · P99 156 ns · max 180 ns
Local GNSS PPS witnessTwo 300 s windows; 522/600 eligible, 78 unavailable. Stable second window: 38.3 ns RMS, 300/300. Downstream relay: 61.9 ns RMS, 451/600, max 211 ns. Physical output and calibrated UTC unqualified.Public protocol proposalW12 fine-clock receiver; empirical RX capture and causal clock mapping.
nRF52 · PToB12 October 2026Passive BLE advertisingHeltec T096 · nRF52840 · one relay
62.5 ns
One-relay PPS-shadow RMSP95 123.25 ns · P99 160.25 ns · max 191 ns
Independent local PPS witness601.576 s; 436/602 usable/nominal (72.425%). RMS includes bias; calibration frozen before validation. GPIO output not independently measured.Public protocol proposalPTP-inspired service contract, profiles, and wire format. Not an adopted standard.
Nordic timeslot demo2016Proprietary radio timeslots100 Hz · no competing stack in the cited test
65.6 ns
Mean GPIO differenceSD 41.0 ns · max 220 ns
Logic-analyzer GPIO comparison30 minutes; 439,445 toggles. Two nearby nRF52 development kits.Open reference codeVendor demo using proprietary timing packets; no standardized BLE time service.
MicroSync2024Connected BLEnRF52840 · central + three peripherals
272 ns
Mean absolute errorSD 319.2 ns · 99% CDF 591.25 ns · RMS not reported
External GPIO comparison · 800 MHzHigh-accuracy scheduling. Bidirectional exchanges and PA/LNA timing signals.Published research protocolBLE connection transport. Synchronization and scheduling described in the paper.
BlueSync2021 / 2022Connectionless BLE beaconsHardware event capture + follow-up timestamps
320 ns
Average sync error per 60 sBest reported setting · single hop
Two commercial BLE SoCs10-minute sessions without resynchronization. Drift-management and packet settings vary.Published research protocolBLE beacon transport. Timing and drift-management methods described in the paper.
CheepSync2015 / 2016BLE advertisingnRF24Cheep broadcasters · Android listeners
~10 µs
Average single-hop accuracyLow-level timestamps and error compensation
Advertiser-to-listener experimentsHeterogeneous passive listeners on resource-constrained hardware.Published research protocolBuilt on Bluetooth 4.0 advertising. Timing service described in the paper.

Rows are ordered by the displayed timing value. RMS, mean absolute error, standard deviation, and mean GPIO difference are distinct statistics measured under different test conditions. The studies do not establish a matched output-accuracy or energy benchmark. BLE transport alone does not define a standardized time service.

Read the measurement methods

Plan a wireless timing deployment

Start with nearby devices. Add a grandmaster standby, extend through relay clocks, and bring time into macOS over USB.

Explore deployment scenarios
GM ACTIVEHOT standby
RC1RC2Clients
One reference. Local clocks across the network.
Explore 1, 2 or 3 GMs, relay depth, LoRa fallback and USB.

From the blog

All articles

Questions about PToB

A starting point for the protocol, the measurements and the work still ahead.

What is PToB?

PToB means Precision Time over BLE, or Bluetooth Low Energy. It is an experimental, PTP-inspired protocol for synchronizing clocks across microcontrollers. Receivers timestamp radio events, recover their transmit times from follow-up data, and track clock offset and drift with a software phase-locked loop (Software PLL). PToB is an independent proposal, not an adopted Bluetooth SIG or IEEE standard. Explore the timing architecture.

How precise is PToB over Bluetooth?

In the 24 October 2026 W12 ESP32-S3 experiment, the delivered BLE clock measured 60.3 ns RMS including bias against independent local PPS observations: 522 of 600 observations were eligible, 78 were unavailable, and the maximum measured error was 180 ns. This is a result for that hardware, path and population. RMS is not a worst-case bound; absolute UTC accuracy and continuous availability remain unqualified. Read the measurements and limits.

Can PToB deliver time to a Mac?

The experimental Apple M-series macOS client receives time through a USB-connected PToB clock and uses a private user-level chrony clock. It leaves the system clock unchanged. Reported shared-source agreement is separate from independent UTC accuracy, and withheld observations remain part of the results. Inspect the USB/macOS findings.

Does PToB support LoRa timing?

PToB has a separate experimental LoRa timing path. The proposed longer-distance extension uses narrower channels, short broadcasts, channel hopping and known-distance propagation correction for fixed installations. Range and delivered precision need measurement; the measured BLE results do not qualify LoRa performance. Read the LoRa design direction.

Jonathan Yantis × GPT 6.1

Jonathan Yantis leads hardware development, protocol design, and research, with GPT 6.1 contributing to implementation, analysis, and documentation.